3D-vision robotic piece picking
The camera looks into the tote, the robot picks single items. Regular cartons need little teaching; new SKUs need samples and grasp data first.
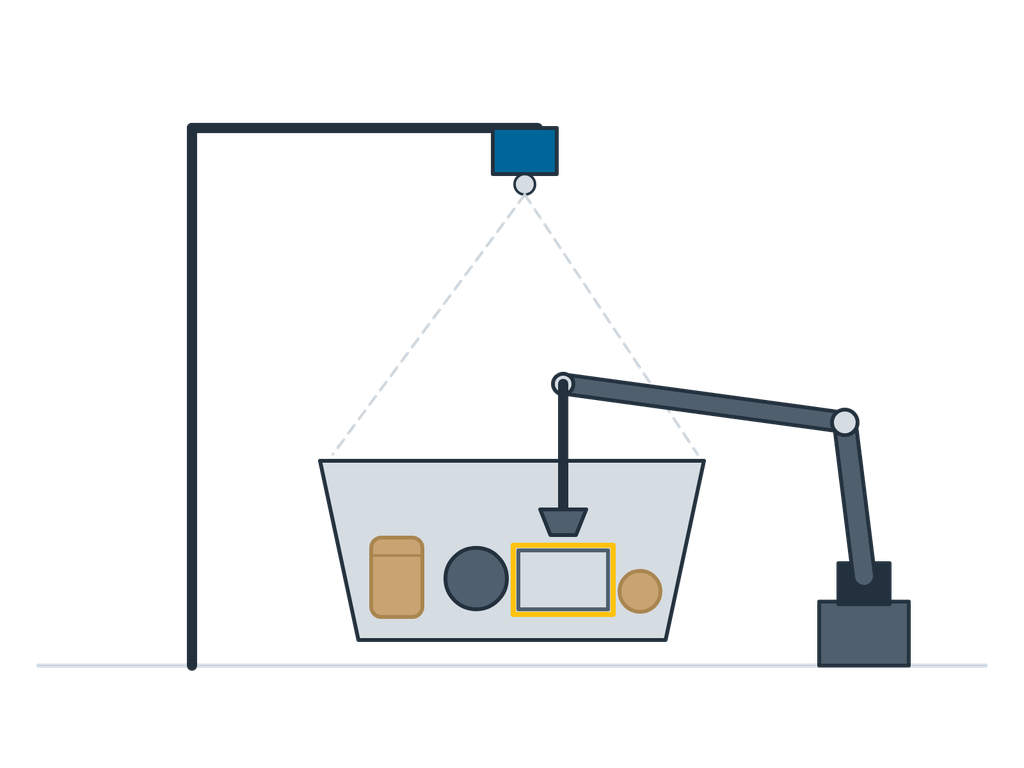
The camera looks into the tote, the robot picks single items. Regular cartons need little teaching; new SKUs need samples and grasp data first.
The camera looks into the tote, the robot picks single items. Regular cartons need little teaching; new SKUs need samples and grasp data first.
A 3D-vision picking cell gives the robot the piece-picking task of taking one item out of a tote. A 3D camera scans the tote, software identifies each item's position and graspable surface, and the robot picks it with a vacuum or finger gripper and places it in the order tote or on a conveyor. Combined with shuttle or case-handling robot systems it enables unmanned picking, and suits e-commerce, pharma and consumer electronics with many SKUs and regular packaging.
| Pick rate | About 500–900 picks/h for regular rigid boxes; polybags, transparent items and mixed SKUs subject to sample tests |
|---|---|
| Item size | 20–400 mm, ≤ 3 kg (extendable) |
| Vision | Structured-light or ToF 3D camera; reflective and transparent packaging to be assessed |
| Gripper | Multi-size vacuum, soft fingers, automatic tool change |
| Recognition | High success rate on regular cartons; polybags, reflective and transparent items need sample tests. Failed items routed to manual handling |
| Robot | 6-axis for deep totes and mixed items; SCARA or delta robots for regular items in shallow totes |
| Interface | Order interface to WMS / WCS |
Figures are typical configuration ranges; exact specifications are set per project.